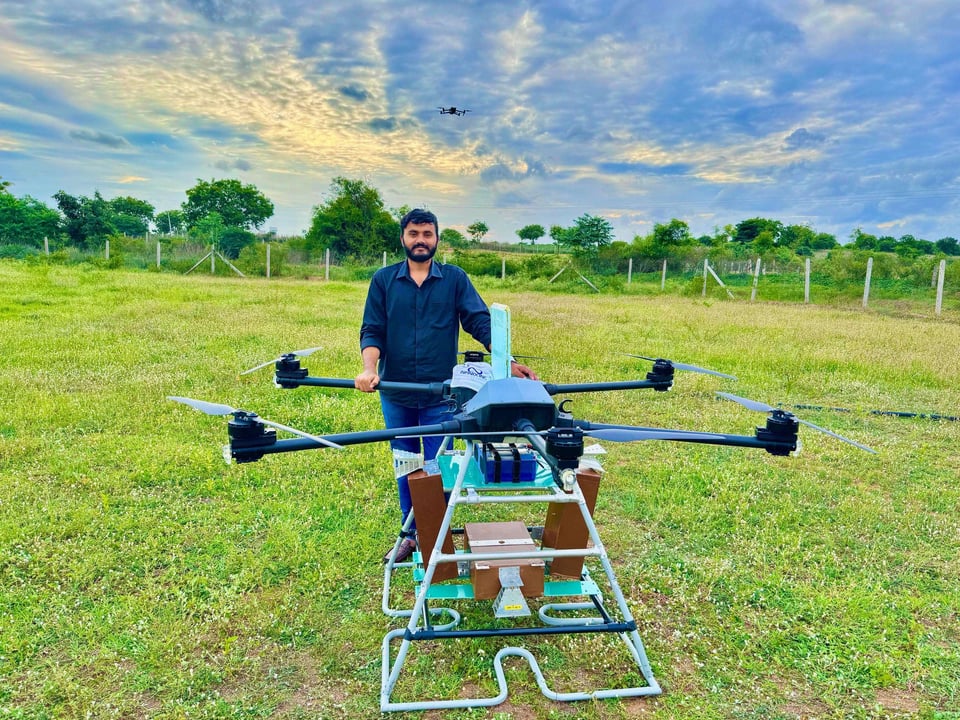
Part 01 / 10
Carbon-fibre frame
Carbon tubes with CNC aluminium joints forming a modular, field-repairable structure.
Coaxial heavy lift
A heavy-lift coaxial (X8) multirotor designed to carry up to 50 kg in demanding environments, combining high-torque industrial motors and large propellers for thrust density, redundancy and operational safety.
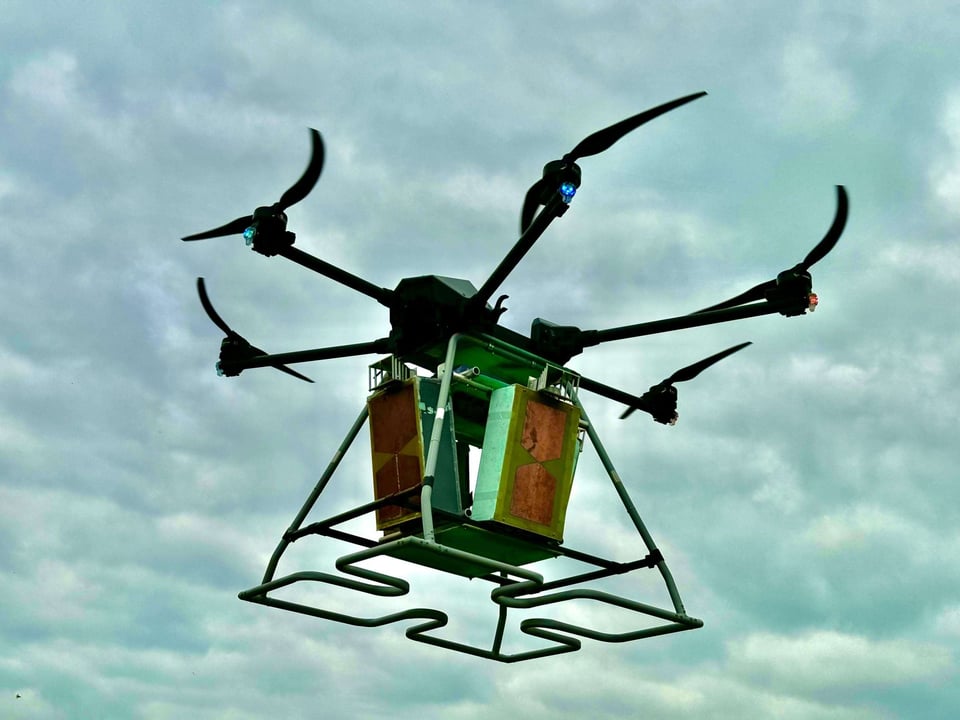
At a glance
Datasheet
| Specification | Value | Status |
|---|---|---|
| Configuration | 4-arm coaxial multirotor (X8) | Status: Listed. |
| Structure | Carbon-fibre tubes with CNC-machined aluminium joints | Status: Listed. |
| Arm diameter | 60–70 mm heavy-duty carbon tubes | Status: Listed. |
| Landing gear | Reinforced skid / shock-absorbing gear | Status: Listed. |
| Design philosophy | Modular, serviceable, field-repairable | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| Motors | High-torque BLDC | Status: Listed. |
| Motor count | 8 (coaxial pairs) | Status: Listed. |
| Propellers | 52–62 in carbon fibre, contra-rotating | Status: Listed. |
| ESCs | High-voltage industrial, 300–400 A class | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| Battery type | High-density Li-ion / Li-Po | Status: Listed. |
| Battery voltage | 24S–28S HV architecture | Status: Listed. |
| Energy management | Integrated BMS and protection | Status: Listed. |
| Power distribution | Custom high-current PCB with fusing | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| Flight controller | H7 supported | Status: Listed. |
| IMUs | Triple-redundant | Status: Listed. |
| Navigation | GNSS + inertial | Status: Listed. |
| Software | ArduPilot | Status: Listed. |
| Safety | Failsafe, RTL, motor-out logic | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| Maximum payload | Up to 50 kg | Status: Listed. |
| Optimal payload | 35–45 kg | Status: Listed. |
| Mounting | Central gravity-balanced payload bay | Status: Listed. |
| Interface | Quick-release / mission-specific | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| MTOW | 90–95 kg | Status: Estimated. |
| Endurance, 50 kg payload | 20–25 min | Status: Estimated. |
| Endurance, 30 kg payload | 30–35 min | Status: Estimated. |
| Cruise speed | 30–45 km/h | Status: Estimated. |
| Max speed | ~60 km/h | Status: Estimated. |
| Operational ceiling | 5,000 m AMSL | Status: Estimated. |
Use cases
Designed for desert, plains, coastal and semi-mountain terrain; functions in dust, light rain and high temperature.
Anatomy
Part 01 / 10
Carbon tubes with CNC aluminium joints forming a modular, field-repairable structure.
Part 02 / 10
60–70 mm carbon tubes, each carrying a coaxial motor pair.
Part 03 / 10
High-torque BLDC motors mounted in coaxial pairs for high thrust density and redundancy.
| Specification | Value | Status |
|---|---|---|
| Count | 8 | Status: Listed. |
Part 04 / 10
52–62 in carbon-fibre propellers.
Part 05 / 10
High-voltage industrial speed controllers, 300–400 A class.
Part 06 / 10
24S–28S high-voltage pack with integrated battery management.
Part 07 / 10
Custom high-current PCB with fusing.
Part 08 / 10
H7 controller with triple-redundant IMUs running ArduPilot.
See AARYA Flight ControllerPart 09 / 10
Central gravity-balanced bay with a quick-release interface.
Part 10 / 10
Reinforced skid / shock-absorbing gear.
Talk to INFINIX INC about configuration, availability and current test status.
Product information on this website is based on supplied project documents and may describe prototypes, development configurations, or estimated performance. Confirm current specifications, test status, regulatory approvals, and availability directly with INFINIX INC.
Related
A modular family of hexacopter UAV platforms in 20 kg, 30 kg and 40 kg payload classes, with common avionics, propulsion philosophy and payload interfaces, for logistics, ISR payload carriage and mission-critical operations.
An STM32H7-based flight controller with dual gyroscopes, eight PWM outputs and support for INAV, ArduPilot, Betaflight and custom firmware, with a 3S–8S input range.