Part 01 / 07
STM32H7 main controller
Main processor running the flight firmware.
| Specification | Value | Status |
|---|---|---|
| MCU | STM32H7 | Status: Listed. |
Flight electronics
An STM32H7-based flight controller with dual gyroscopes, eight PWM outputs and support for INAV, ArduPilot, Betaflight and custom firmware, with a 3S–8S input range.
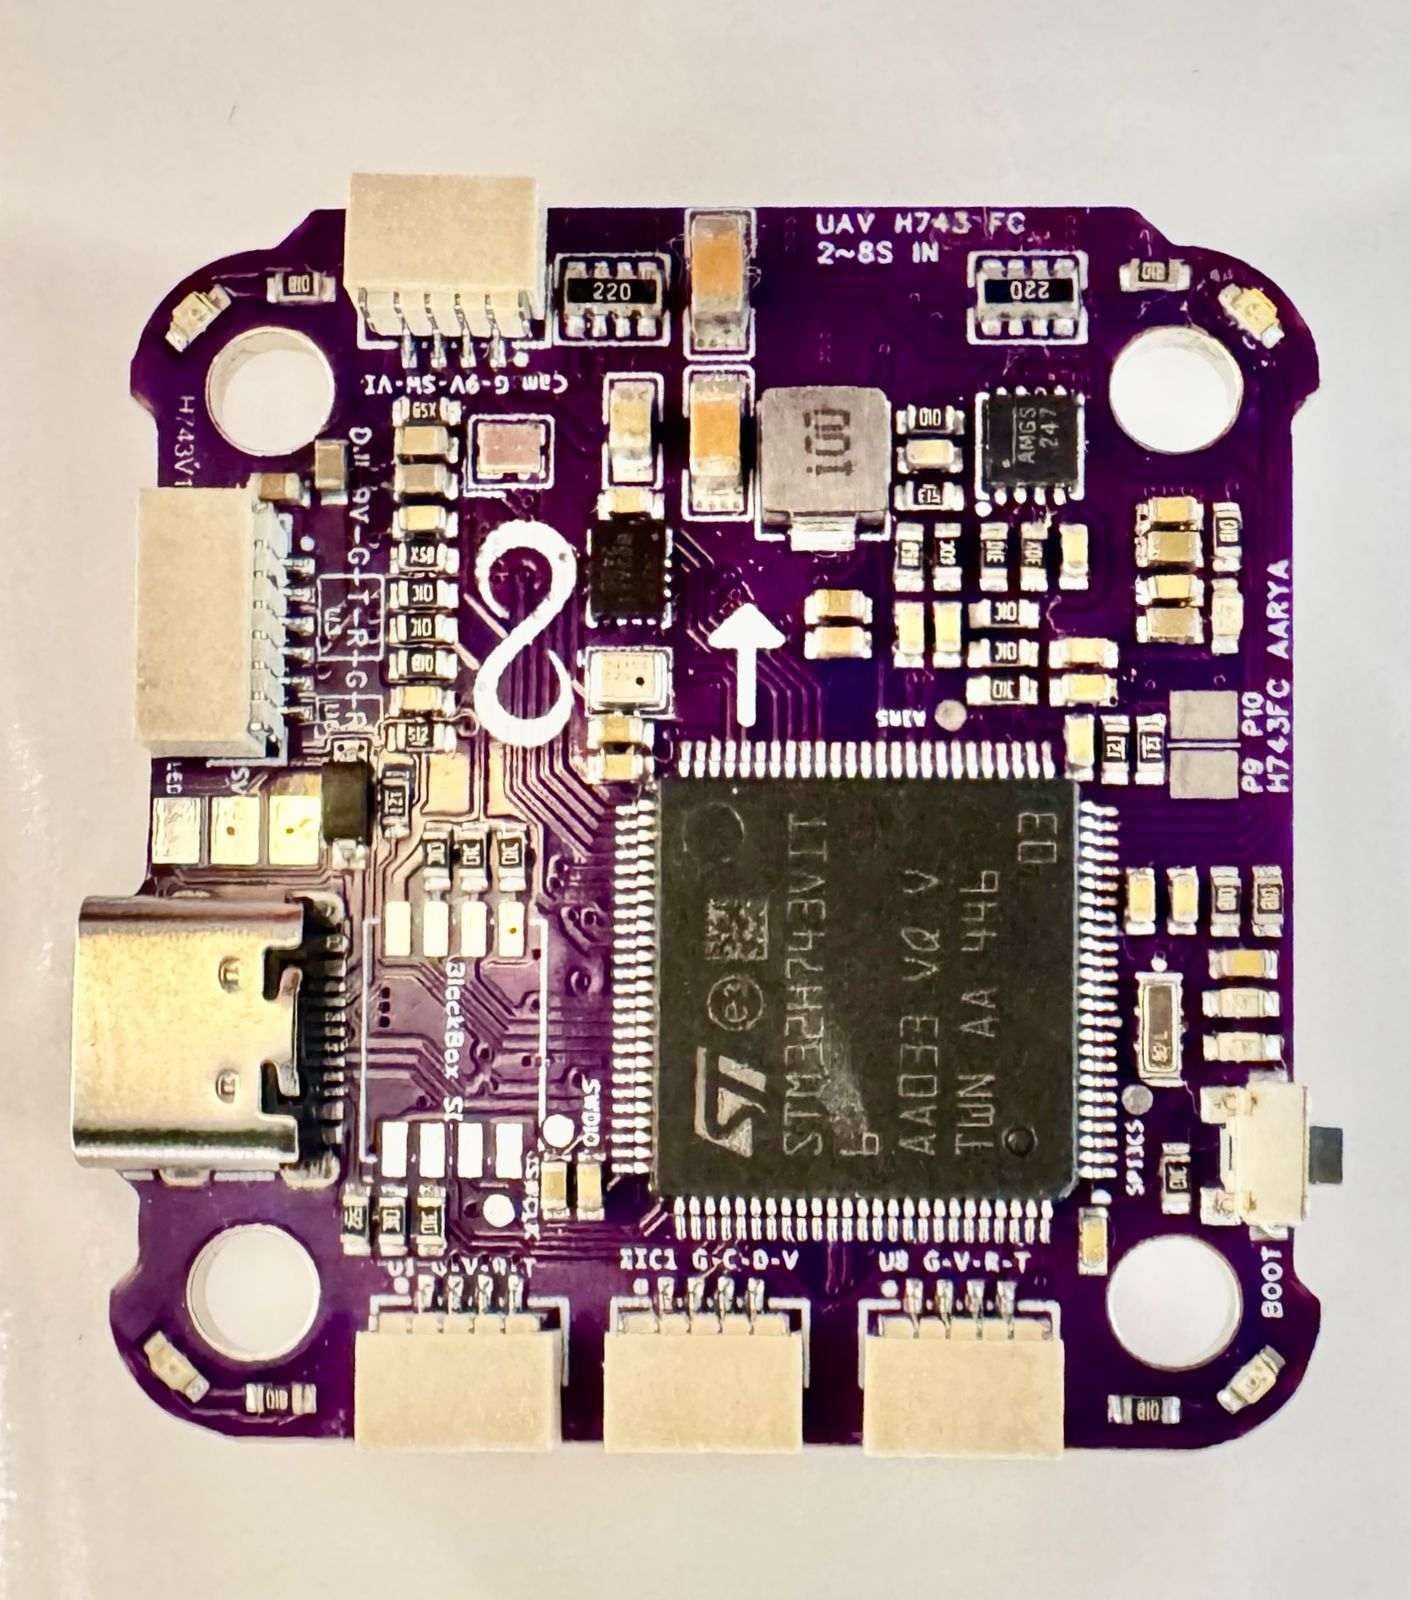
At a glance
Datasheet
| Specification | Value | Status |
|---|---|---|
| Main controller | STM32H7 | Status: Listed. |
| Gyroscopes | ICM42688 + MPU6500, ±2000 °/s, 32 kHz sampling | Status: Listed. |
| Accelerometers | ±16 g (±156.96 m/s²) | Status: Listed. |
| Gyro noise floor | ~15 µ°/s/√Hz | Status: Listed. |
| Accel noise floor | ~120 µg/√Hz | Status: Listed. |
| OSD | AT7456E (analog overlay) | Status: Listed. |
| OPT receiver | ESP8285 (UART6) | Status: Listed. |
| ESC outputs | 8 PWM channels | Status: Listed. |
| Servo outputs | 2 channels | Status: Listed. |
| BEC outputs | 5 V @ 2 A, 9 V @ 3 A | Status: Listed. |
| Input voltage | 10 V to 40 V (3S to 8S) | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| Max roll rate | 500–720 °/s (configurable) | Status: Listed. |
| Max pitch rate | 300–600 °/s | Status: Listed. |
| Max yaw rate | 200–400 °/s | Status: Listed. |
| G-force sensing | ±16 g | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| Firmware | INAV, ArduPilot, Betaflight and custom | Status: Listed. |
| Max waypoints | Up to 999 (ArduPilot) | Status: Listed. |
| GPS update rate | Up to 10 Hz (module dependent) | Status: Listed. |
| Airspeed sensor | Supported (pitot via SPL06) | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| UART ports | 7 (UART1–4, 6–8) | Status: Listed. |
| I²C | IIC1 external; IIC2 internal use only | Status: Listed. |
| SPI | SPI 3 (pad) | Status: Listed. |
| Telemetry | MAVLink / Satcom | Status: Listed. |
| RC link latency | 2–20 ms depending on protocol | Status: Listed. |
| Specification | Value | Status |
|---|---|---|
| Mounting | 30.5 × 30.5 mm, Φ4.0 mm | Status: Listed. |
| Operating temperature | −15 °C to +75 °C | Status: Listed. |
Use cases
Anatomy
Part 01 / 07
Main processor running the flight firmware.
| Specification | Value | Status |
|---|---|---|
| MCU | STM32H7 | Status: Listed. |
Part 02 / 07
Dual gyroscopes (ICM42688 + MPU6500) and accelerometers for attitude sensing.
| Specification | Value | Status |
|---|---|---|
| Gyro range | ±2000 °/s, 32 kHz | Status: Listed. |
Part 03 / 07
AT7456E analog on-screen display overlay.
Part 04 / 07
ESP8285 on UART6.
Part 05 / 07
Accepts 10–40 V and provides 5 V @ 2 A and 9 V @ 3 A outputs.
Part 06 / 07
8 PWM ESC outputs, 2 servo outputs and 7 UART ports.
Part 07 / 07
Configuration and firmware flashing.
Talk to INFINIX INC about configuration, availability and current test status.
Product information on this website is based on supplied project documents and may describe prototypes, development configurations, or estimated performance. Confirm current specifications, test status, regulatory approvals, and availability directly with INFINIX INC.
Related
A modular family of hexacopter UAV platforms in 20 kg, 30 kg and 40 kg payload classes, with common avionics, propulsion philosophy and payload interfaces, for logistics, ISR payload carriage and mission-critical operations.
A heavy-lift coaxial (X8) multirotor designed to carry up to 50 kg in demanding environments, combining high-torque industrial motors and large propellers for thrust density, redundancy and operational safety.